P1 · PANEL / ROI / AXIS GROUND TRUTH
原 EXE 对齐基准真值复核
所有保存均写入追加式审计事件;旧标注、旧比较和旧提取结果不会被删除或覆盖。
gray_or_same_color
pending
PMID 41286676
Safety and efficacy of pimavanserin in patients with Lewy body dementia experiencing dementia-related psychosis in the HARMONY study.
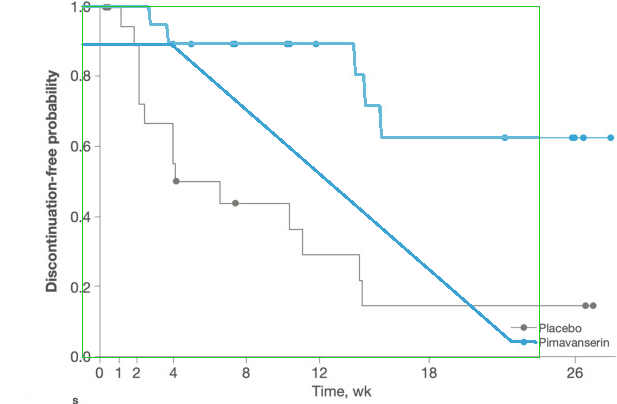
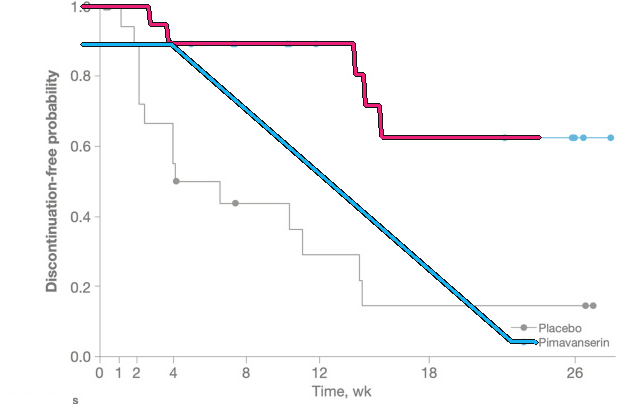
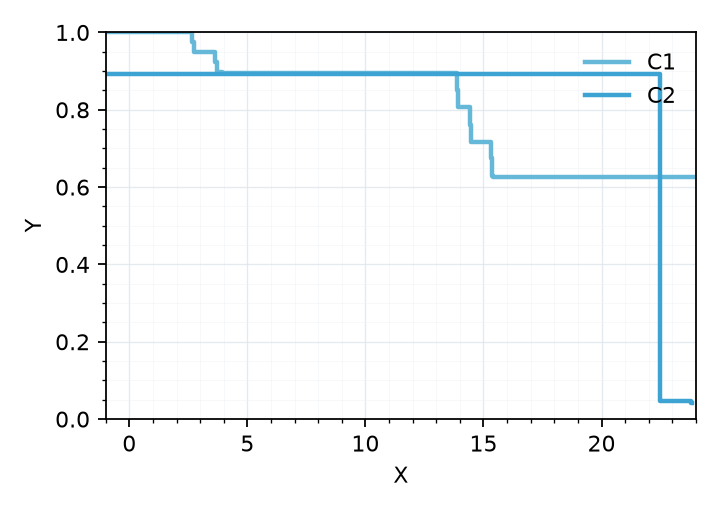
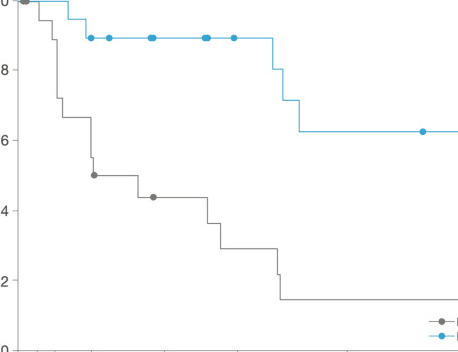
Fig3 · Panel Fig._3a · Time to Discontinuation for any Reason
Fig. 3 Kaplan–Meier Estimation of Time to Discontinuation for any Reason in Patients With PDD + DLB. a DLB, dementia with Lewy bodies; ITT, intention-to-treat; PDD, Parkinson’s disease dementia. a Double-blind ITT analysis set坐标框复核
洋红 = 当前 Linux 候选;绿色 = 已保存人工真值。没有绿色框表示仍未形成真值。

当前候选 {'x0': 134, 'y0': 6, 'x1': 592, 'y1': 358}
人工真值 {'x0': 134, 'x1': 592, 'y0': 6, 'y1': 358}
查看候选 OCR 与警告(只能作种子,不能自证真值)
{
  "complete": true,
  "engine": "RapidOCR",
  "plot_bottom": 357,
  "plot_left": 134,
  "plot_right": 591,
  "plot_top": 6,
  "warnings": [],
  "x_axis_y": 357,
  "x_confidence": 0.966,
  "x_detected": true,
  "x_max": 24,
  "x_min": -1,
  "x_ticks": [
    {
      "box": [
        [
          220.0,
          366.0
        ],
        [
          231.0,
          366.0
        ],
        [
          231.0,
          379.0
        ],
        [
          220.0,
          379.0
        ]
      ],
      "confidence": 0.9995334148406982,
      "pixel": 225.5,
      "text": "4",
      "value": 4.0
    },
    {
      "box": [
        [
          293.0,
          366.0
        ],
        [
          304.0,
          366.0
        ],
        [
          304.0,
          379.0
        ],
        [
          293.0,
          379.0
        ]
      ],
      "confidence": 0.9993715882301331,
      "pixel": 298.5,
      "text": "8",
      "value": 8.0
    },
    {
      "box": [
        [
          362.0,
          365.0
        ],
        [
          382.0,
          365.0
        ],
        [
          382.0,
          381.0
        ],
        [
          362.0,
          381.0
        ]
      ],
      "confidence": 0.9991776645183563,
      "pixel": 372.0,
      "text": "12",
      "value": 12.0
    },
    {
      "box": [
        [
          471.0,
          365.0
        ],
        [
          491.0,
          365.0
        ],
        [
          491.0,
          380.0
        ],
        [
          471.0,
          380.0
        ]
      ],
      "confidence": 0.9990994930267334,
      "pixel": 481.0,
      "text": "18",
      "value": 18.0
    },
    {
      "box": [
        [
          616.0,
          364.0
        ],
        [
          638.0,
          364.0
        ],
        [
          638.0,
          381.0
        ],
        [
          616.0,
          381.0
        ]
      ],
      "confidence": 0.9995867311954498,
      "pixel": 627.0,
      "text": "26",
      "value": 26.0
    }
  ],
  "y_axis_x": 152,
  "y_confidence": 0.997,
  "y_detected": true,
  "y_max": 1,
  "y_min": 0,
  "y_ticks": [
    {
      "box": [
        [
          124.0,
          2.0
        ],
        [
          143.0,
          2.0
        ],
        [
          143.0,
          12.0
        ],
        [
          124.0,
          12.0
        ]
      ],
      "confidence": 0.9921978314717611,
      "pixel": 7.0,
      "text": "1.0",
      "value": 1.0
    },
    {
      "box": [
        [
          122.0,
          69.0
        ],
        [
          145.0,
          69.0
        ],
        [
          145.0,
          83.0
        ],
        [
          122.0,
          83.0
        ]
      ],
      "confidence": 0.998722493648529,
      "pixel": 76.0,
      "text": "0.8",
      "value": 0.8
    },
    {
      "box": [
        [
          120.0,
          138.0
        ],
        [
          146.0,
          138.0
        ],
        [
          146.0,
          155.0
        ],
        [
          120.0,
          155.0
        ]
      ],
      "confidence": 0.9986686110496521,
      "pixel": 146.5,
      "text": "0.6",
      "value": 0.6
    },
    {
      "box": [
        [
          120.0,
          209.0
        ],
        [
          145.0,
          209.0
        ],
        [
          145.0,
          225.0
        ],
        [
          120.0,
          225.0
        ]
      ],
      "confidence": 0.9983741044998169,
      "pixel": 217.0,
      "text": "0.4",
      "value": 0.4
    },
    {
      "box": [
        [
          120.0,
          279.0
        ],
        [
          145.0,
          279.0
        ],
        [
          145.0,
          296.0
        ],
        [
          120.0,
          296.0
        ]
      ],
      "confidence": 0.9982545773188273,
      "pixel": 287.5,
      "text": "0.2",
      "value": 0.2
    },
    {
      "box": [
        [
          120.0,
          349.0
        ],
        [
          146.0,
          349.0
        ],
        [
          146.0,
          365.0
        ],
        [
          120.0,
          365.0
        ]
      ],
      "confidence": 0.9976116021474203,
      "pixel": 357.0,
      "text": "0.0",
      "value": 0.0
    }
  ]
}
追加一条审查结论
选择“有效 KM”时,四边 ROI、四个坐标范围、Panel、终点和曲线数均为必填。
追加式审计历史
最新事件仅作为当前缓存;以下每一条既往结论都永久保留。
| 事件 | 时间 / 审查人 | 状态 | ROI | 坐标 | 说明 |
|---|---|---|---|---|---|
| #36p1-visual-axis-audit-v2 · frozen benchmark contact sheets + original images + RapidOCR re-audit | 2026-07-28T15:12:18+00:00Codex-assisted visual audit | valid_km | {'x0': 134, 'x1': 592, 'y0': 6, 'y1': 358} |
X 0.0–28.0 / Y 0.0–1.0 |
P1 冻结原图审查;人工检查冻结原图刻度;ROI 四边按可见坐标轴框记录。 |
最近一次正式比较
Suite #3 · 2026-07-28T15:15:12+00:00
真值完整 117 / 120;通过 0;缺真值 0;无效案例 3。